One real ECU is enough
The tool plays every other node, so bench work starts the day the first ECU arrives.
 RE4AAutomotive engineering & security tools
Rest-bus simulation plays every other node from your own network matrix, so one real ECU sees the traffic it expects.
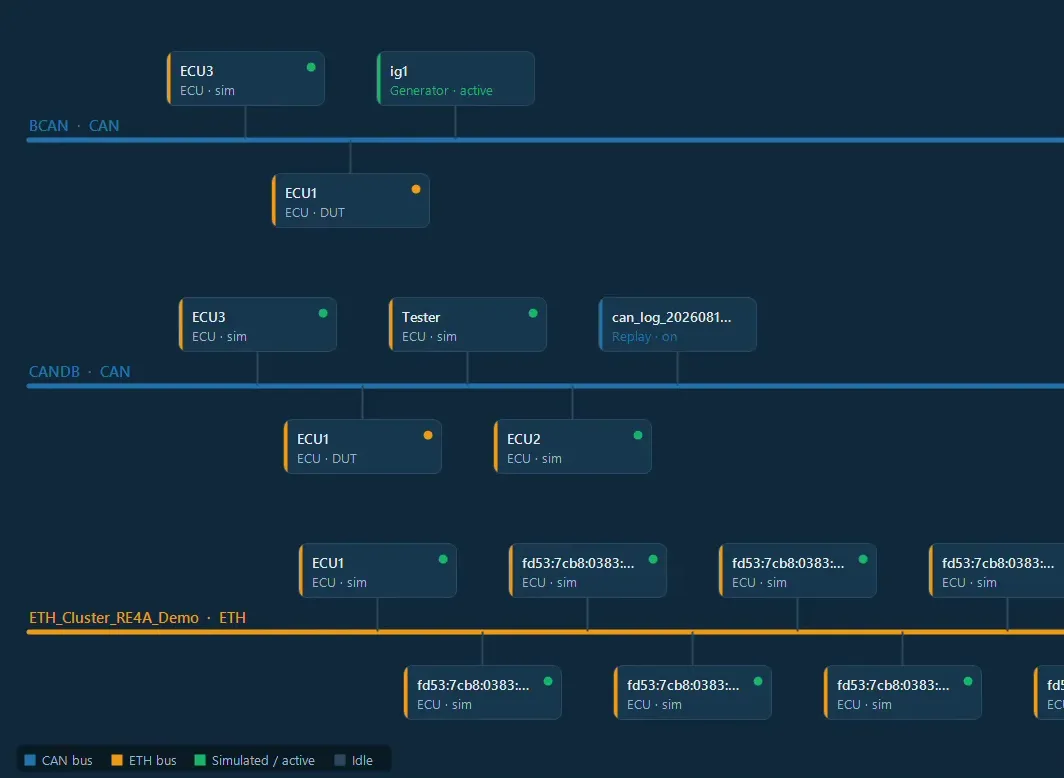
The tool plays every other node, so bench work starts the day the first ECU arrives.
Cyclic traffic is rebuilt from the DBC or ARXML you import, so the ECU never faces a silent bus.
A virtual CAN channel runs the whole setup with no bus hardware, so an evaluation ships nothing.
Scope
Capabilities
Every node but the ECU under test sends its cyclic frames from the imported matrix.
Record CAN to BLF and Ethernet to PCAP; replay at recorded timing, the ECU's own frames left out.
Send a single frame or a cyclic stream on any bus; Ethernet over IPv4, IPv6 or raw layer 2.
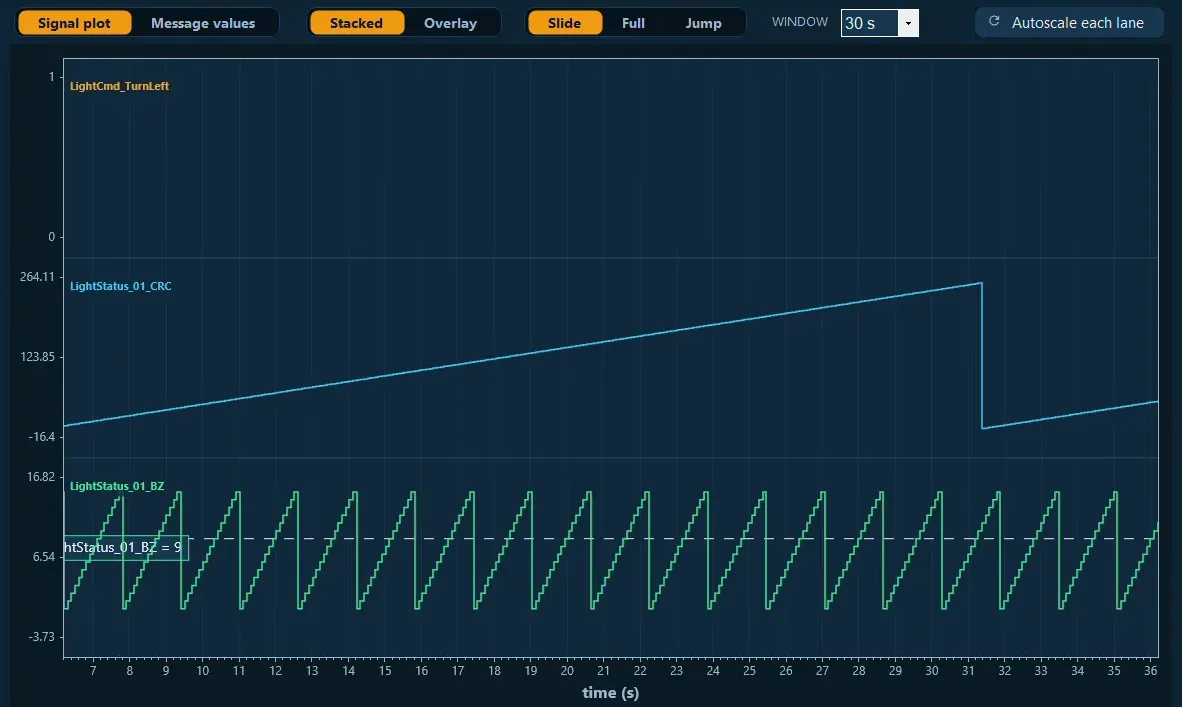
Push a chosen value onto one declared signal; the cyclic payload updates in place.
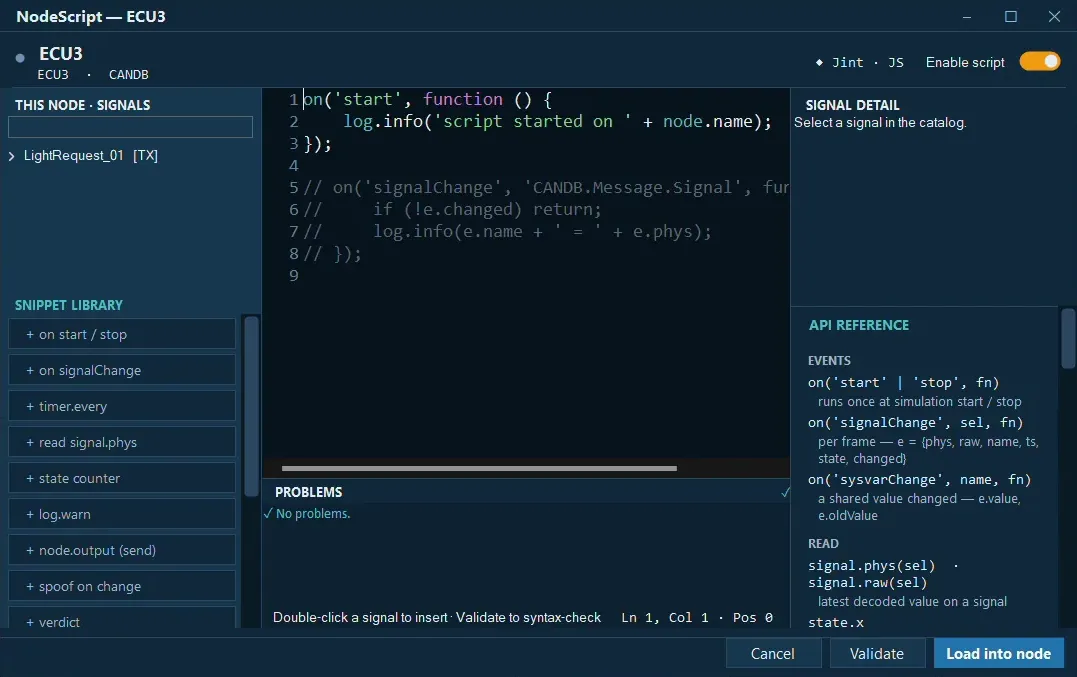
JavaScript per simulated node: react to traffic, send frames, run UDS, record a verdict.
Signal plots, a database explorer, a diagnostic console and a trace viewer that decodes captures.
In action
Testing Simulation is the Simulation edition of Testing Studio. Add it to the Pentest or Fuzz edition, or license it on its own for the bench.
Datasheet
Evaluate it
Rest-bus simulation around one real ECU. No hardware needed.